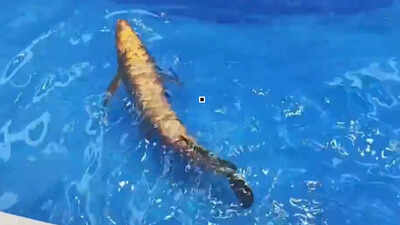
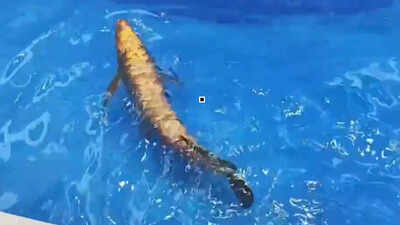
China has showcased a highly realistic fish-shaped underwater robot that can autonomously navigate through water, highlighting the country’s growing development of biomimetic robotic systems with potential applications in underwater surveillance and reconnaissance.According to Chinese news outlet Jimu News, BG-5 Golden Dragon Fish, developed by Boyagongdao Marine Technology Group, was demonstrated at the 2026 China International Fair for Trade in Services (CIFTIS) in Beijing’s Shougang Park. The robot is modelled on the golden arowana and uses a multi-joint tail to reproduce the swimming motion of a real fish.Jimu News quoted an exhibition staff member as saying that the robot does not follow a pre-programmed swimming route. Instead, its sensors detect obstacles and allow it to autonomously plan its movement. The report said the robot weighs 3 kg and has a three-joint tail divided into seven segments.According to the company product catalogue, the BG-5 is 640 mm long, 204 mm wide and 90 mm high, with a weight of 3 kg. It has a listed maximum operating depth of 5 metres and a maximum speed of 0.6 metres per second.The robot uses fish-tail propulsion, with its multi-joint tail generating movement through an undulating motion rather than relying on a conventional propeller. For navigation, the BG-5 is designed with autonomous obstacle-avoidance capabilities.The manufacturer also lists a BG-5V variant associated with capabilities including path planning, task allocation, formation control and multi-robot cooperation.Potential defence applicationsBoyagongdao, the developer of the BG-5, has an established defence connection in underwater robotics. The company says it has undertaken a national defence key special project involving an underwater biomimetic detection platform.It has also developed the ROBO-SHARK biomimetic underwater robot in cooperation with a military unit, according to material published by the World Robot Conference.The BG-5 fish-like form and autonomous navigation could potentially make it useful for shallow-water reconnaissance and surveillance. Its small 3-kg form factor could allow it to operate in confined or shallow underwater environments where larger unmanned underwater vehicles may be less practical. Its fish-like, multi-joint propulsion could support low-profile underwater surveillance.Its BG-5V variant with its path planning, task allocation, formation control and multi-robot coordination, potentially enabling multiple underwater robots to conduct coordinated search, surveillance and reconnaissance missions.